


CoRL 2026
MobiAgent: Dual-Loop Recursive Policy Self-Improvement for Long-Horizon Mobile Manipulation
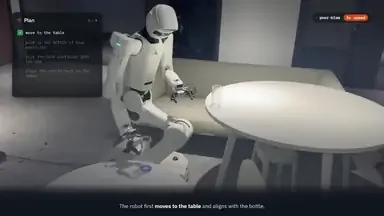
One loop plans, executes, and recovers during a task. A second loop revisits those runs to discover and refine skills for future tasks.
Embodied AI & robot learning
I am a student in the Computer Vision and Machine Intelligence (CVMI) Lab at the University of Hong Kong, where I will begin my PhD with Prof. Xiaojuan Qi on . I develop embodied agents that learn from the consequences of their actions. My long-term goal is to build robots that understand what people need and work alongside them in everyday life.

We released Long-WAM, a world-action model that uses a longer visual history for real-time robot control.
Our CoRL 2026 paper MobiAgent is now on arXiv. It shows how mobile robots can learn new skills from their own task attempts.
We introduced MG-Nav, which uses a sparse memory of previously visited places to guide a robot to a visual goal.
CoRL 2026
One loop plans, executes, and recovers during a task. A second loop revisits those runs to discover and refine skills for future tasks.
arXiv · 2026
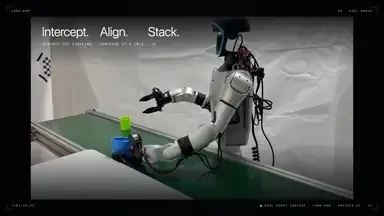
Long-WAM uses a longer history of camera observations to track motion and task progress while controlling a robot in real time.

arXiv · 2025
A robot remembers places it has seen, finds a route to a target shown in a photograph, and uses local geometry to navigate between waypoints.

Incoming PhD student
Advised by Prof. Xiaojuan Qi
Starting
Hong Kong
Master’s studies in Electrical and Computer Engineering
Hong Kong

Bachelor’s degree in Communication Engineering
Xi’an, China